Projects

ADAS
3D Object Detection
- End-to-end LiDAR-based detector
- Real-time visualization with predicted bounding boxes
- Multi-threaded pipeline for data loading, inference and display

ADAS
3D Detection & Tracking on Edge
- Fusion of LiDAR and camera data
- High-performance detection on edge devices
- Real-time SORT tracking with remote monitoring via websockets

ADAS
3D Point Cloud Scene Reconstruction
- Unified interface for NuScenes, DDAD and KITTI
- Self-supervised learning without ground-truth depth
- Integrated 3D visualization with CamViz

ADAS
2D Panoptic Segmentation
- Real-time inference on PC and edge devices
- Multi-threaded architecture with teacher–student distillation
- Prototype web app built with Gradio

ADAS
2D Object Detection
- Fast, lightweight model on Jetson edge devices
- Real-time display with minimal latency
- Web prototype with Gradio

Smart Factory
Multi-Camera Human Intrusion Detection
- Multi-camera surveillance for industrial safety
- Real-time instance segmentation
- Multi-threading and multi-processing pipeline
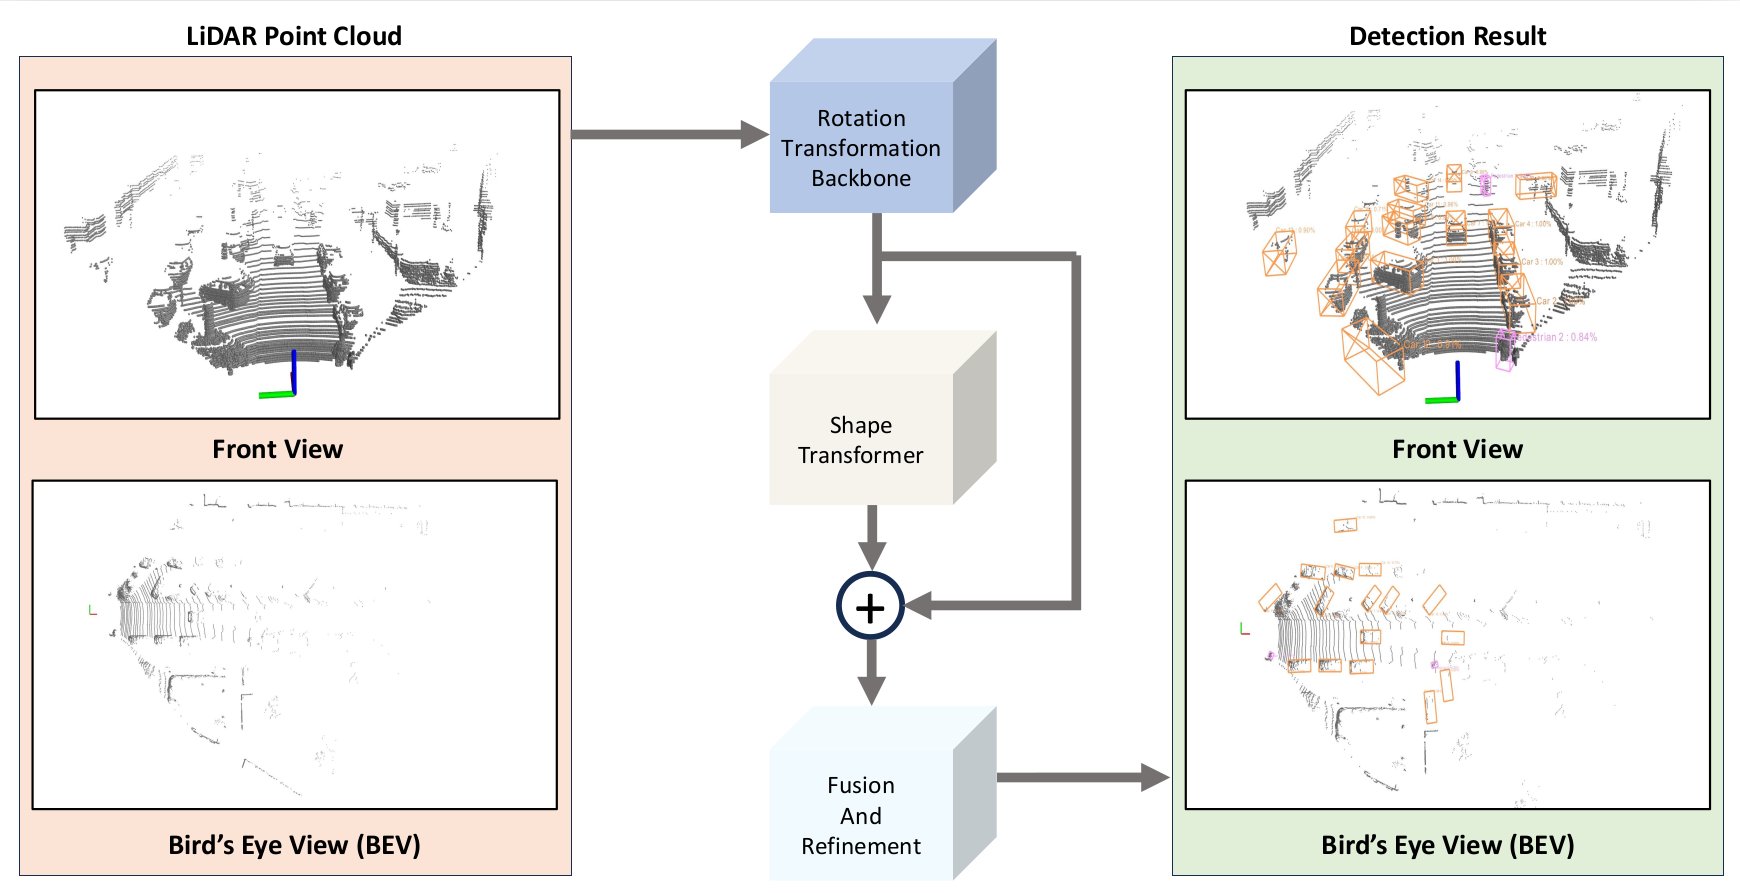
Research
3D Object Detection with Spatial Shape Transformer
A Transformer-based 3D detector that models object dimensions and spatial relationships for accurate LiDAR detection.
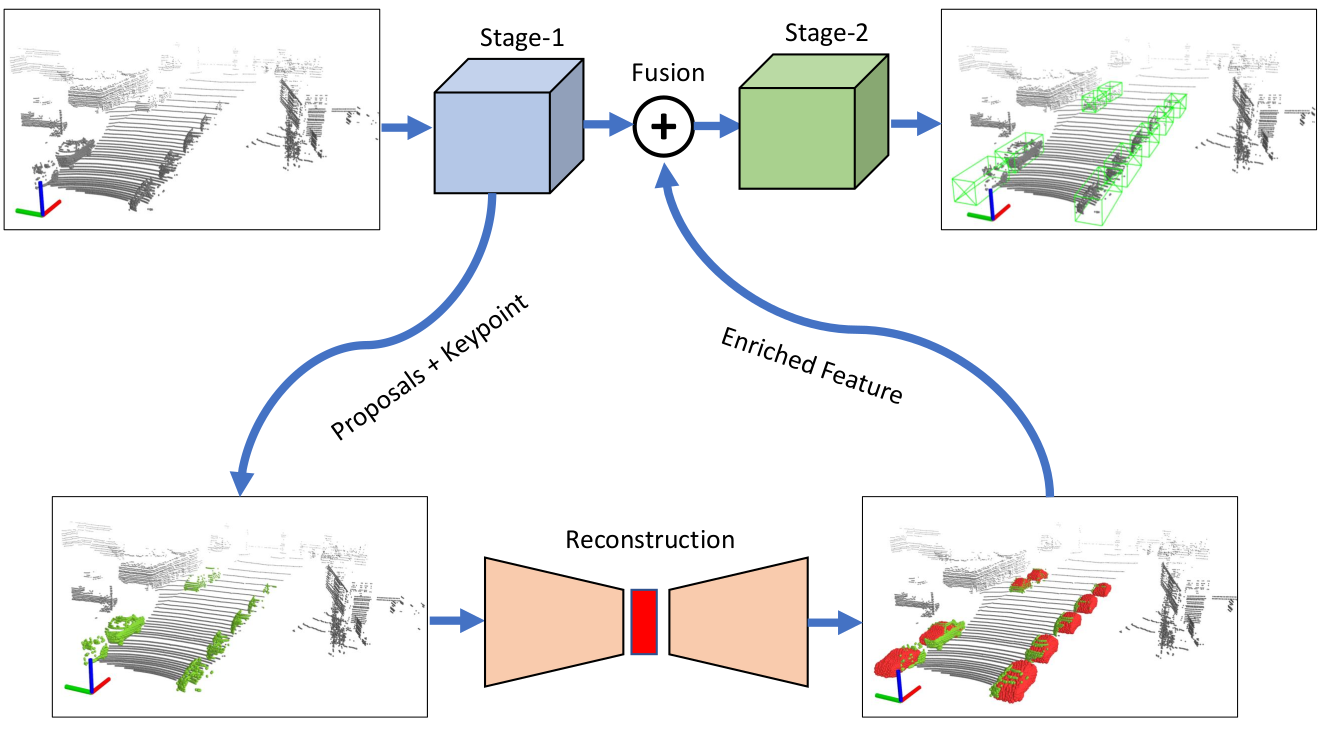
Research
3D Detector for Occluded Objects
A point–voxel framework that produces high-quality 3D boxes for occluded objects while preserving shape context.
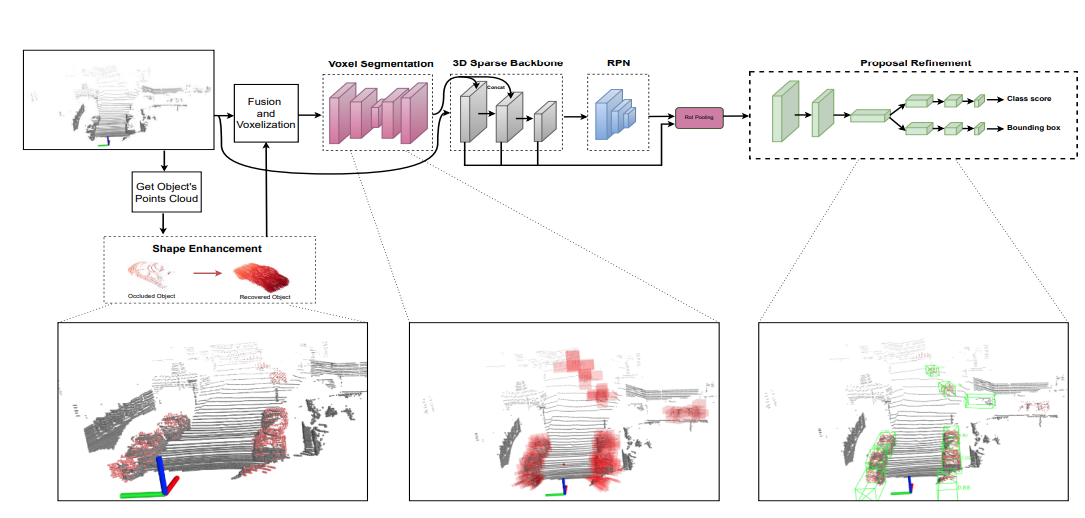
Research
Improving Object Shape in 3D Detection
Improves object-shape accuracy of 3D detectors with a lightweight, quantized model.
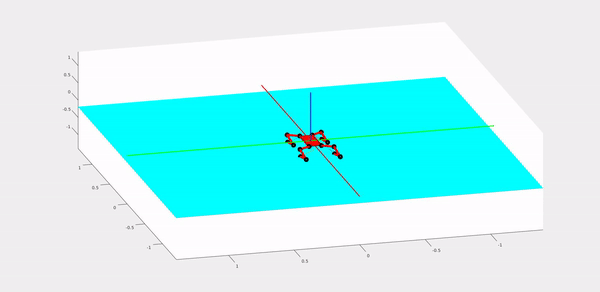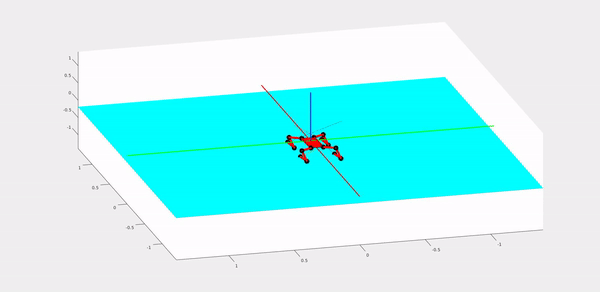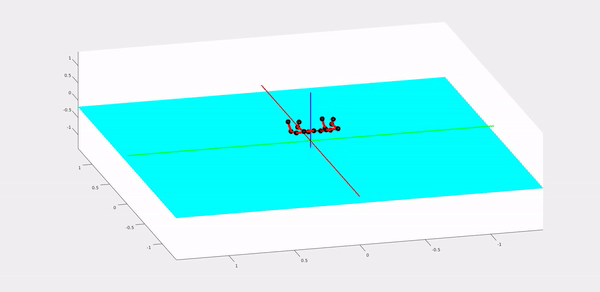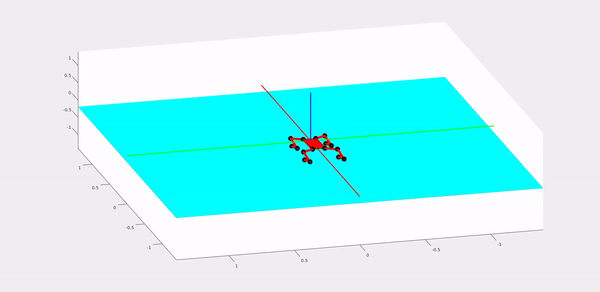
Robotics
Jumping Optimization for Quadruped Robots
Optimizing jump trajectories for the Unitree A1 quadruped in MATLAB and ROS/Gazebo.